Discover how Edge AI Computer turns Jetson Orin NX into a deliverable AGV/AMR controller with 4x GMSL2, isolated CAN FD, Y-board IO expansion, and OOB remote maintenance.
Case Details
The AGV/AMR Controller Challenge: A 10 ms Perception-to-Action Loop Needs More Than Compute
For stable obstacle avoidance, the perception-to-action loop in an AMR/AGV needs to be within 10 ms. That requirement is not satisfied by inference performance alone. The hardware must simultaneously provide sufficient camera input density and deterministic industrial bus communication.
A typical AMR needs forward navigation cameras, side obstacle-avoidance cameras, and rear collision-avoidance cameras. That means four or more camera channels are often required at the same time. The controller also needs isolated CAN FD or RS485 to communicate with the chassis, send speed and steering commands, and connect LiDAR, IMU, collision sensors, and emergency-stop signals. If any of these elements is missing, the compute module may be powerful, but the vehicle-level system is not engineering-deliverable.
This is where many Orin NX-based designs face a gap. The module can run the models, but the carrier and controller must solve camera cabling, industrial IO, power protection, thermal range, and remote maintenance. EA250 Pro is configured almost directly against this AMR/AGV requirement list.
EA250 Pro Configuration: Built Around Multi-Camera and Chassis Integration
EA250 Pro provides four GMSL2 channels with FAKRA Z connectors and PoC coaxial power. In industrial vision, the decisive advantage of GMSL2 is not only bandwidth but physical distance and connection reliability. Coaxial cable can transmit over 15 meters, while MIPI CSI-2 ribbon cables are typically limited to around 30 centimeters. FAKRA latches provide significantly better retention force under vibration than USB and flat ribbon cables. PoC combines data and power over a single coaxial cable, reducing cabling complexity for multi-camera deployments by more than 50%.
For an AMR/AGV, this maps directly to vehicle architecture. Four GMSL2 channels can support forward navigation, side obstacle avoidance, and rear collision avoidance, while allowing cameras to be placed at the physical locations required by the vehicle rather than clustered around the controller. This is especially important when the controller is installed in a protected compartment and cameras are distributed around the chassis.
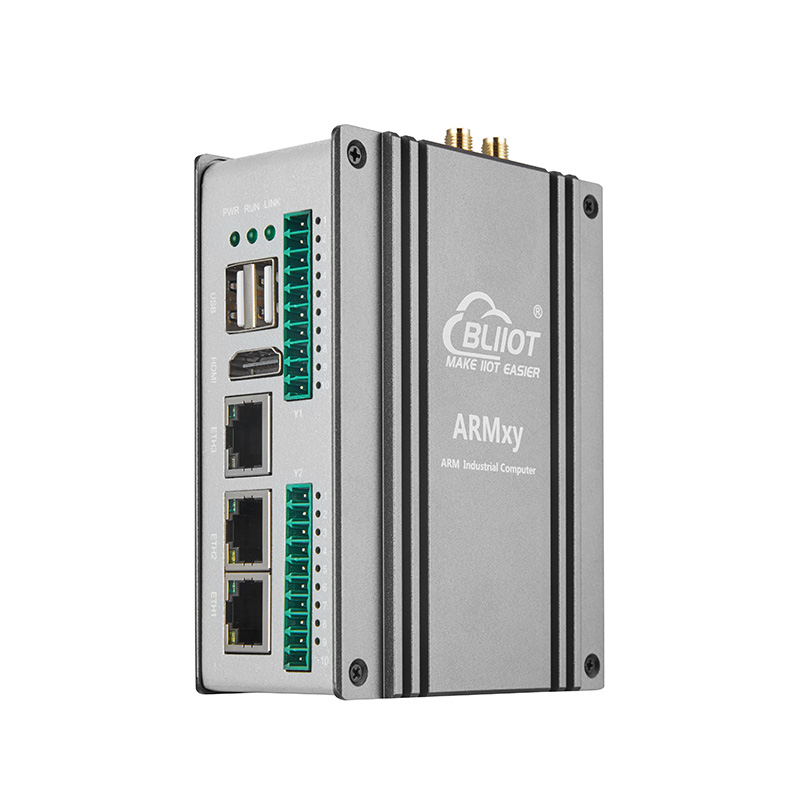
On the chassis communication side, EA250 Pro provides onboard 1× isolated CAN FD and 1× isolated RS485/RS232. Through the Y board, this can be expanded to 2× CAN FD, 4× RS485, and 16DI/8DO. That IO set covers chassis speed and steering commands, LiDAR and IMU access, collision sensors, and emergency-stop signals. In other words, the controller is not only a compute carrier; it is also an industrial bus hub.
The hardware is also designed for mobile deployment. The all-aluminum enclosure, -20°C to +75°C operating temperature, 12–24V wide voltage input, ESD ±6kV contact/±8kV air protection, and EFT 2kV power protection allow EA250 Pro to be installed directly on a mobile platform without an additional protective enclosure. For AMRs deployed in logistics warehouses or at the far end of production lines, the optional OOB out-of-band management module provides a remote maintenance channel independent of the main system. This matters because not every deployed AMR can be rebooted on site whenever the system crashes. For remote deployments, the OOB channel is itself part of operability.
How the Compute and IO Divide the Work
In this architecture, Orin NX 16GB acts as the compute pool. Its 157 TOPS INT8 can run visual SLAM, dynamic obstacle avoidance, path planning, and target detection in parallel. EA250 Pro acts as the industrial bus hub and deployment carrier. It turns inference results into chassis-executable commands through CAN FD or RS485, and it provides the camera interfaces, IO expansion, power protection, thermal range, and remote management required by the vehicle.
It is important to define the boundary correctly. Orin NX and EA250 Pro do not replace the chassis controller to perform deterministic motion planning itself. The appropriate role of Orin NX is perception-driven narrow-domain inference and mid-tier VLA, with multi-model parallel inference and real-time scheduling in the AMR. The chassis controller remains responsible for deterministic execution. EA250 Pro connects the two worlds: the AI perception stack on one side and the industrial chassis network on the other.
Aetina’s palm-sized in-vehicle edge AI system based on Orin NX, with 4× GMSL2 FAKRA Z supporting AMR surround monitoring and obstacle detection, has already validated the compute sufficiency of Orin NX on multi-camera mobile platforms. The EA250 Pro case extends that logic into a controller-level deployment: the question is not only whether the module can run the models, but whether the complete hardware can be installed, wired, protected, and maintained on the vehicle.
Selection Guidance: EA250 Standard vs. EA250 Pro
For AGV/AMR projects, the choice between EA250 standard and EA250 Pro depends on camera topology and IO requirements.
The EA250 standard version is the compute-priority, standardized-interface option. It provides 157 TOPS with 4× USB 3.0 and onboard isolated CAN FD/RS485. It is suitable for vision inference nodes or AMR/AGV deployments where cameras connect through USB or network and IO requirements do not require additional expansion.
The EA250 Pro is the option for projects that do not want to compromise between camera expansion and industrial IO. It provides 4× GMSL2, Y-board expansion to 2× CAN FD/4× RS485/16DI/8DO, and OOB remote management. It is suitable for AMRs that require multi-camera physical deployment, multiple actuators and sensors, wide-temperature protection, and remote operability.